MR 환경 내비게이션 개발 프로젝트
프로젝트 개요
- 프로젝트 명: MR환경 내비게이션 프로젝트
- 역할
- Topology Map 생성 알고리즘 개발
- MR 환경 내비게이션 앱 개발
- 프로젝트 통합 및 리딩
- 문서화
- 개발 환경
- Unity 2022
- C#
- HoloLens 2/MR
- 기간: 2022.01 ~ 2022.12
- 인원: 3명
논문 링크
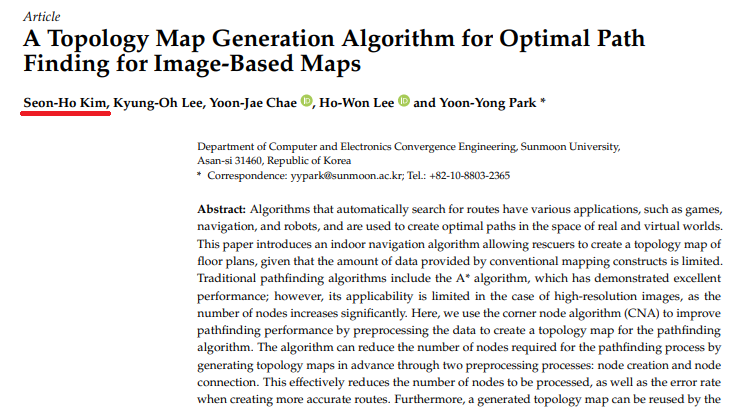
A Topology Map Generation Algorithm for Optimal Path Finding for Image-Based Maps
프로젝트 배경
- MR 기반 실내 재난 모니터링 및 구조 시스템 연구의 일부
- 건물 구조 데이터 부재 → 도면 기반으로 빠르게 Topology Map 생성 필요
- MR HMD의 낮은 컴퓨팅 파워, 구조 임무 특성 상 오류 없는 경로 안내 필수
- 적절한 Pathfinding 최적화가 요구되어 자체 알고리즘 연구 진행
전체 요약 (핵심 키워드)
- Mixed Reality(MR) 환경 실내 내비게이션 시스템 개발
- 자체 개발 CNA 알고리즘으로 도면 기반 그래프 생성
- Pathfinding 노드 수 90% 이상 감소, A* 기반 경로 탐색
- Unity + MRTK 기반 MR 안내 시스템 구현
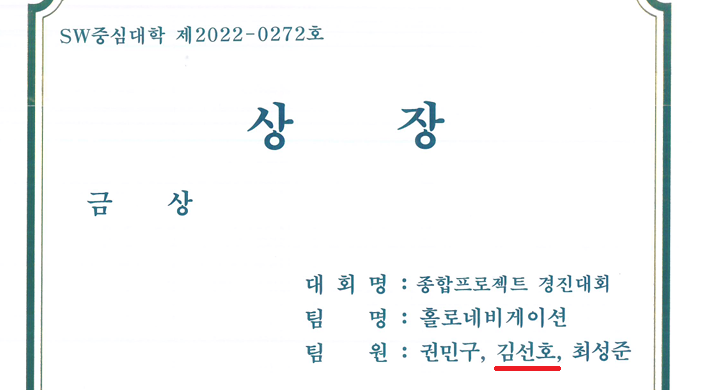
- SCI-E 저널 논문 1저자, 경진대회 금상
- 팀 리딩(회의/문서화/커뮤니케이션)
주요 구현 내용
1. 도면 기반 Topology Map 생성 알고리즘 (CNA)
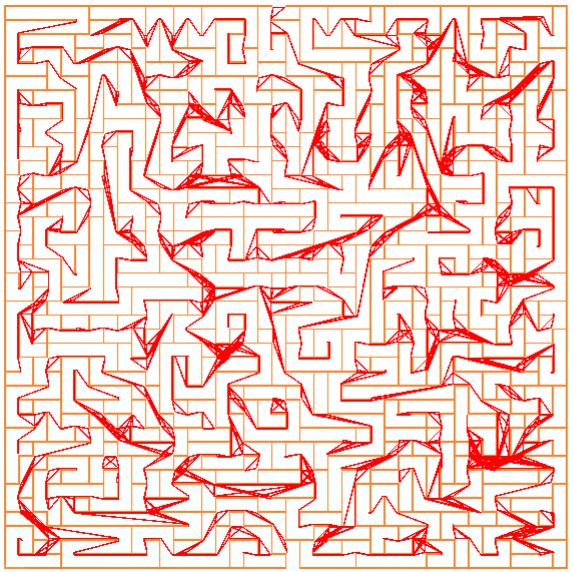 Topology Map 생성 결과물
그래프 정점 개수 감소율
| Complexity | A* | A* With CNA | Percentage |
|---|---|---|---|
| Very Simple | 46062.5 | 39 | −99.92% |
| Simple | 122703 | 102.2 | −99.92% |
| Intermediate | 107462.6 | 147.2 | −99.86% |
| Complicated | 176671.1 | 200.8 | −99.89% |
| Very Complicated | 759311.4 | 380.8 | −99.95% |
| Special Case | 143376.6 | 260 | −99.82% |
| 기능 | 설명 |
|---|---|
| 이미지 → Grid 변환 | 도면을 이미지 처리해 타일맵 형태(Grid)로 변환 |
| 노드 생성 | 벽 영역에서 코너 검출 후 노드 생성 |
| 그래프 구성 | 생성된 노드들을 연결해 Topology Map 구축 |
| 최적화 | Pathfinding에 필요한 노드 수 90% 이상 감소 |
핵심 포인트
- 일반적인 A* 단독 적용 시 넓은 공간에서 잘못된 경로 생성 문제를 해결
- 도면 기반 그래프 생성(Corner Node Algorithm, CNA)을 통해 정확한 노드만 추출
- 결과적으로 오류 없는 경로 + 고성능 탐색 실현
코드 스니펫
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
35
36
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
69
// Corner Node Algorithm을 구현하는 클래스의 일부분입니다.
public class CornerNodeAlgorithmV2
{
    private int[,] direction = {
        {1, 0}, {1, 1}, {0, 1}, {-1, 1},
        {0, -1}, {-1, -1}, {-1, 0}, {1, -1}
    };

    private int width, height;

    private Cell[,] mapData;
    private List<PathNode> pNodeList = new List<PathNode>();
    private List<(int, int)> wallList;

    private void createCorner(int x, int y, int beforeDirection)
    {
        if (x < 0 || y < 0 || x >= width || y >= height)
            return; // Out of range

        if (mapData[x, y].Type == Constants.CHECK)
            return; // Checked cell

        if (mapData[x, y].Type == Constants.OPEN) // is Corner?
        {
            int wallCount = 0;

            for (int i = 0; i < 8; i++)
            {
                int nextX = x + direction[i, 0];
                int nextY = y + direction[i, 1];

                if (!(nextX < 0 || nextY < 0 || nextX >= width || nextY >= height))
                {
                    if (mapData[nextX, nextY].Type == Constants.WALL ||
                        mapData[nextX, nextY].Type == Constants.CHECK)
                    {
                        wallCount++;
                    }
                }

                if (wallCount > 1) break;
            }

            if (wallCount == 1)
            {
                mapData[x, y].Type = Constants.NODE;
                pNodeList.Add(new PathNode(x, y));
            }

            return;
        }

        if (mapData[x, y].Type == Constants.WALL)
        {
            mapData[x, y].Type = Constants.CHECK;

            int backward = directionSelector(beforeDirection - 4);

            for (int i = 0; i < 7; i++)
            {
                int nextDirection = directionSelector(backward + i);
                int nextX = x + direction[nextDirection, 0];
                int nextY = y + direction[nextDirection, 1];

                createCorner(nextX, nextY, nextDirection);
            }
        }
    }
}
2. A* Algorithm 기반 경로 탐색
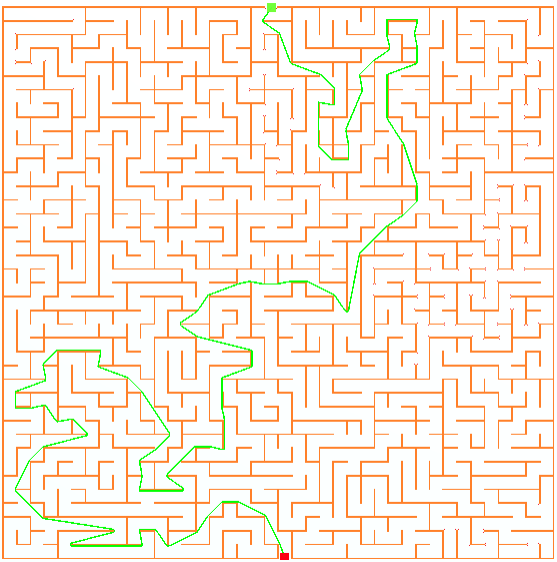 생성된 Topology Map에 A*를 적용한 결과물
A* 단일 적용 vs A* + 최적화 적용 결과 표
| Complexity | Preprocessing Time | A* | A* with CNA | Percentage |
|---|---|---|---|---|
| Very Simple | 7 ms | 75.8 ms | 1.2 ms | -90.77% |
| Simple | 46.2 ms | 264.2 ms | 2.5 ms | -99.05% |
| Intermediate | 90.4 ms | 183.8 ms | 2.8 ms | -98.48% |
| Complicated | 280.8 ms | 775.5 ms | 6.7 ms | -99.14% |
| Very Complicated | 1137.2 ms | 3342.1 ms | 9.7 ms | -99.71% |
| Special Case | 582.8 ms | 557.6 ms | 5.5 ms | -99.01% |
| 항목 | 내용 |
|---|---|
| 탐색 알고리즘 | A* (Straight-line Distance Heuristic) |
| 적용 대상 | CNA로 생성한 Topology Map Graph |
| 효과 | ↓ 노드 수 감소 → MR HMD에서도 빠른 연산 속도 확보 |
핵심 포인트
- 목적지까지의 직선 거리(Heuristic) 사용
- 그래프 기반 탐색으로 경로 오류 제거
- 기존 Grid 탐색 대비 성능 대폭 향상
코드 스니펫
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
35
36
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
69
70
71
72
73
74
75
76
77
78
79
80
81
82
83
84
85
86
87
88
// A* 알고리즘을 적용하기 위한 메소드입니다.
private void aStarAlgorithm(AStarNode ptr)
{
    do
    {
        ptr = addCloseList();
        addOpenList(ptr);

        if (ptr.GetNode == targetNode && ptr.GetNode == targetNode)
        {
            Debug.Log("Pathfinding Complete (A* + CNA)");
            while (true)
            {
                pathResult.Add(new Vector3(ptr.GetNode.getX(), 0, ptr.GetNode.getY()));
                if (ptr.GetNode.getX() == startNode.getX() &&
                    ptr.GetNode.getY() == startNode.getY())
                {
                    return;
                }
                ptr = ptr.ParentNode;
            }
        }

    } while (openList.Count != 0);

    Debug.Log("Can't find path");
}

// 선택된 노드 중 아직 탐색하지 않은 노드를 리스트에 추가합니다.
private void addOpenList(AStarNode ptr)
{
    for (int i = 0; i < ptr.GetNode.getCnn().Count; i++)
    {
        Tuple<PathNode, Vector3> nodeBuffer = ptr.GetNode.getCnn()[i];

        double hScore = Math.Sqrt(
            Math.Pow(targetNode.getX() - nodeBuffer.Item1.getX(), 2) +
            Math.Pow(targetNode.getY() - nodeBuffer.Item1.getY(), 2));

        double gScore = Math.Sqrt(
            Math.Pow(ptr.GetNode.getX() - nodeBuffer.Item1.getX(), 2) +
            Math.Pow(ptr.GetNode.getY() - nodeBuffer.Item1.getY(), 2))
            + ptr.GScore;

        double fScore = hScore + gScore;

        if (nodeBuffer.Item1.Status == 0) // When a node doesn't belong any list
        {
            AStarNode newAStarNode = new AStarNode(nodeBuffer.Item1, hScore, gScore, ptr);
            openList.Add(newAStarNode);

            nodeBuffer.Item1.Status = 1;
            nodeBuffer.Item1.AStarNode = newAStarNode;
            nodeBuffer.Item1.FScore = newAStarNode.FScore;
        }
        else if (nodeBuffer.Item1.Status == 1) // When a node belong to open list
        {
            if (fScore < nodeBuffer.Item1.FScore)
            {
                nodeBuffer.Item1.AStarNode.GScore = gScore;
                nodeBuffer.Item1.AStarNode.HScore = hScore;
                nodeBuffer.Item1.AStarNode.FScore = fScore;
                nodeBuffer.Item1.AStarNode.ParentNode = ptr;
            }
        }
    }
}

// 탐색한 노드를 리스트에 추가합니다
private AStarNode addCloseList()
{
    if (openList.Count != 0)
    {
        AStarNode minNode = openList[0];
        for (int i = 0; i < openList.Count; i++)
        {
            if (minNode.FScore > openList[i].FScore)
                minNode = openList[i];
        }

        minNode.GetNode.Status = 2;
        closeList.Add(minNode);
        openList.Remove(minNode);
        return minNode;
    }

    return null;
}
3. MR 내비게이션 시스템 구현 (Unity + MRTK)
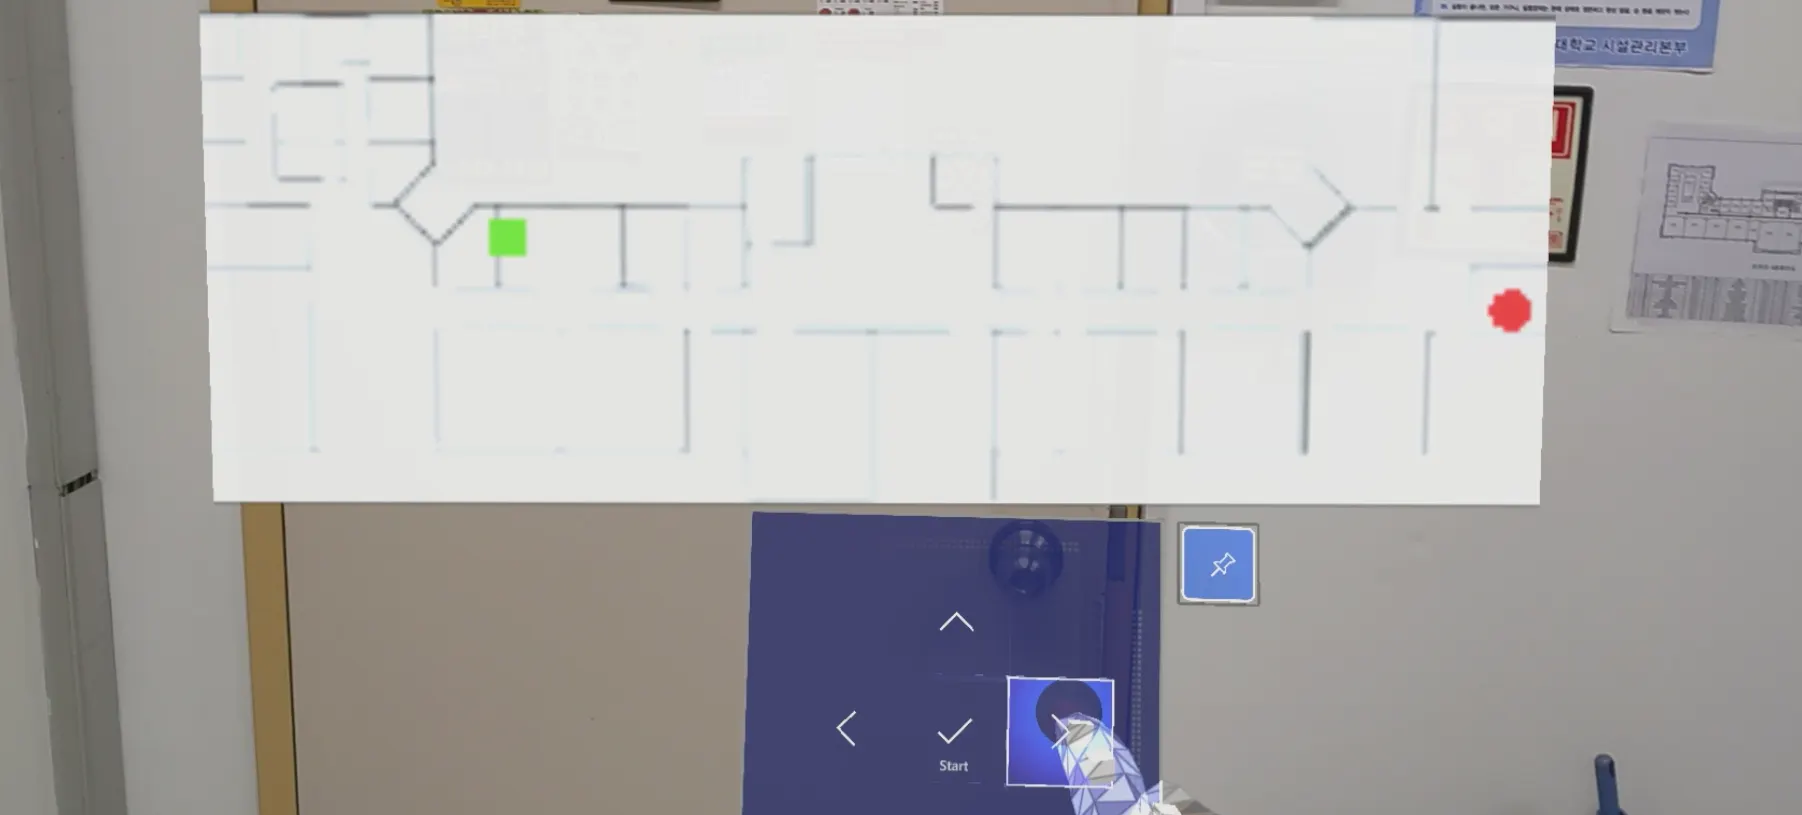 목적지 지정
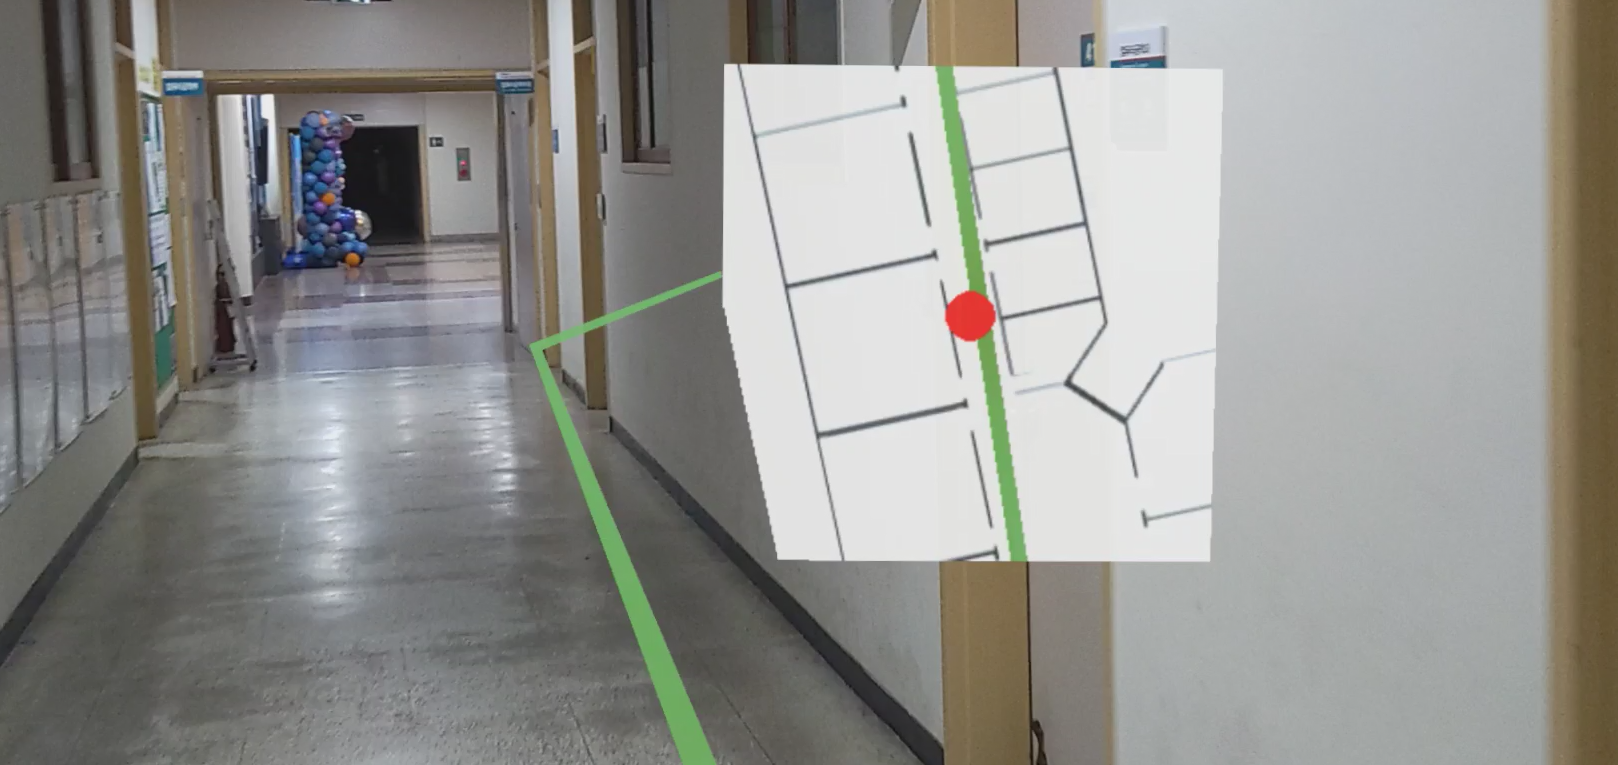 경로 안내
| 기술 | 내용 |
|---|---|
| 엔진 | Unity |
| MR Framework | MRTK(Mixed Reality Toolkit) |
| 기능 | 생성된 경로 위에 3D 안내 오브젝트를 실시간 표시 |
| 결과 | 사용자 시야에 최단경로를 시각적으로 제공하는 내비게이션 구현 |
핵심 포인트
- Unity 사용으로 3D 오브젝트 처리 용이
- MRTK 활용해 HMD 제스처·공간 인식 자연스럽게 연동
프로젝트 매니지먼트
| 항목 | 수행 내용 |
|---|---|
| 회의 관리 | 주간 회의를 주관, 이슈 공유 및 주간 목표 설정 |
| 문서화 | 진행 상황·회의록 작성 → Google Cloud로 공유 |
| 커뮤니케이션 | Git·Discord·KakaoTalk 기반 실시간 이슈 관리 및 화면 공유 |
| 협업 문화 | 문제 상황을 팀 단위로 즉시 공유하여 빠르게 해결 |
핵심 포인트
- 팀 리딩 역할 수행
- 문서화 및 커뮤니케이션 체계적 운영
- 실시간 협업 환경 구축으로 프로젝트 효율 향상